Data-Mediated Self-ImprovingTUCOProbing Data Value
Building self-improving robotic systems that decide what to learn next.
My research lies at the intersection of data-centric learning, self-improving systems, and sim-to-real reinforcement learning. I study how robots can decide what experience to acquire, what data to retain, and what to learn next.
I am building robot agents and skill harnesses that connect simulation-trained experts, visual skills, and real-world feedback. These systems support skill selection, composition, and execution evaluation, enabling robots to continually refine their skills and the experience they learn from.
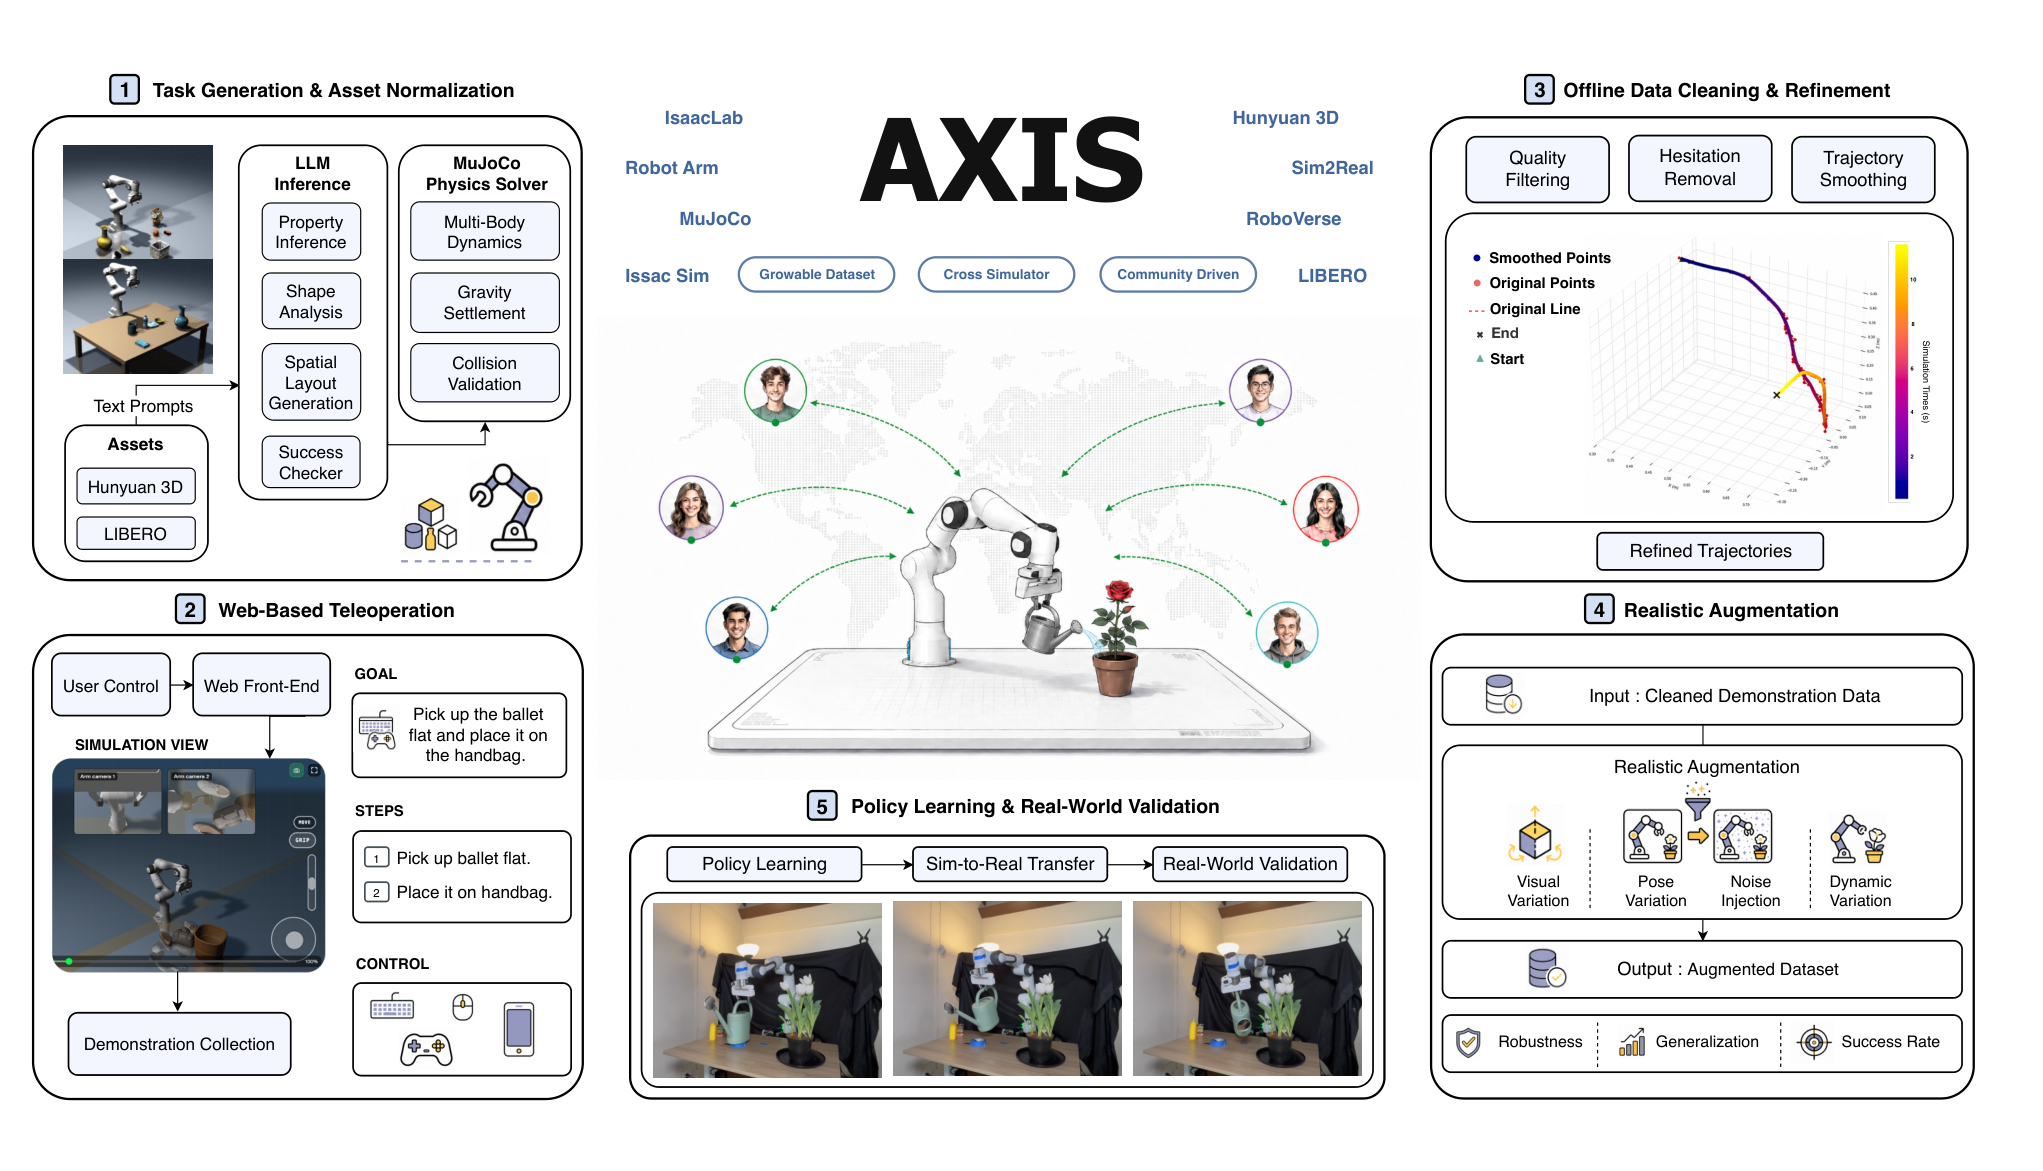
At Axis Robotics, backed by a $12 million seed round, I lead a team of approximately 15 researchers and engineers. As CTO, I set our research direction and oversee team organization, departmental budgeting, and resource allocation.
I am mentored by Jianfei Yang and Jindou Jia at NTU, and collaborate with Jiachen Li at Georgia Tech.
Research Map
Axis Dataset V1
Co-Adaptive DAggerEvolving Skills
Co-Adaptive DAggerTUCO
Evolving Skills
AURAAPEXΔ Flow MatchingCODE
General
Model
Model
Recent Publication
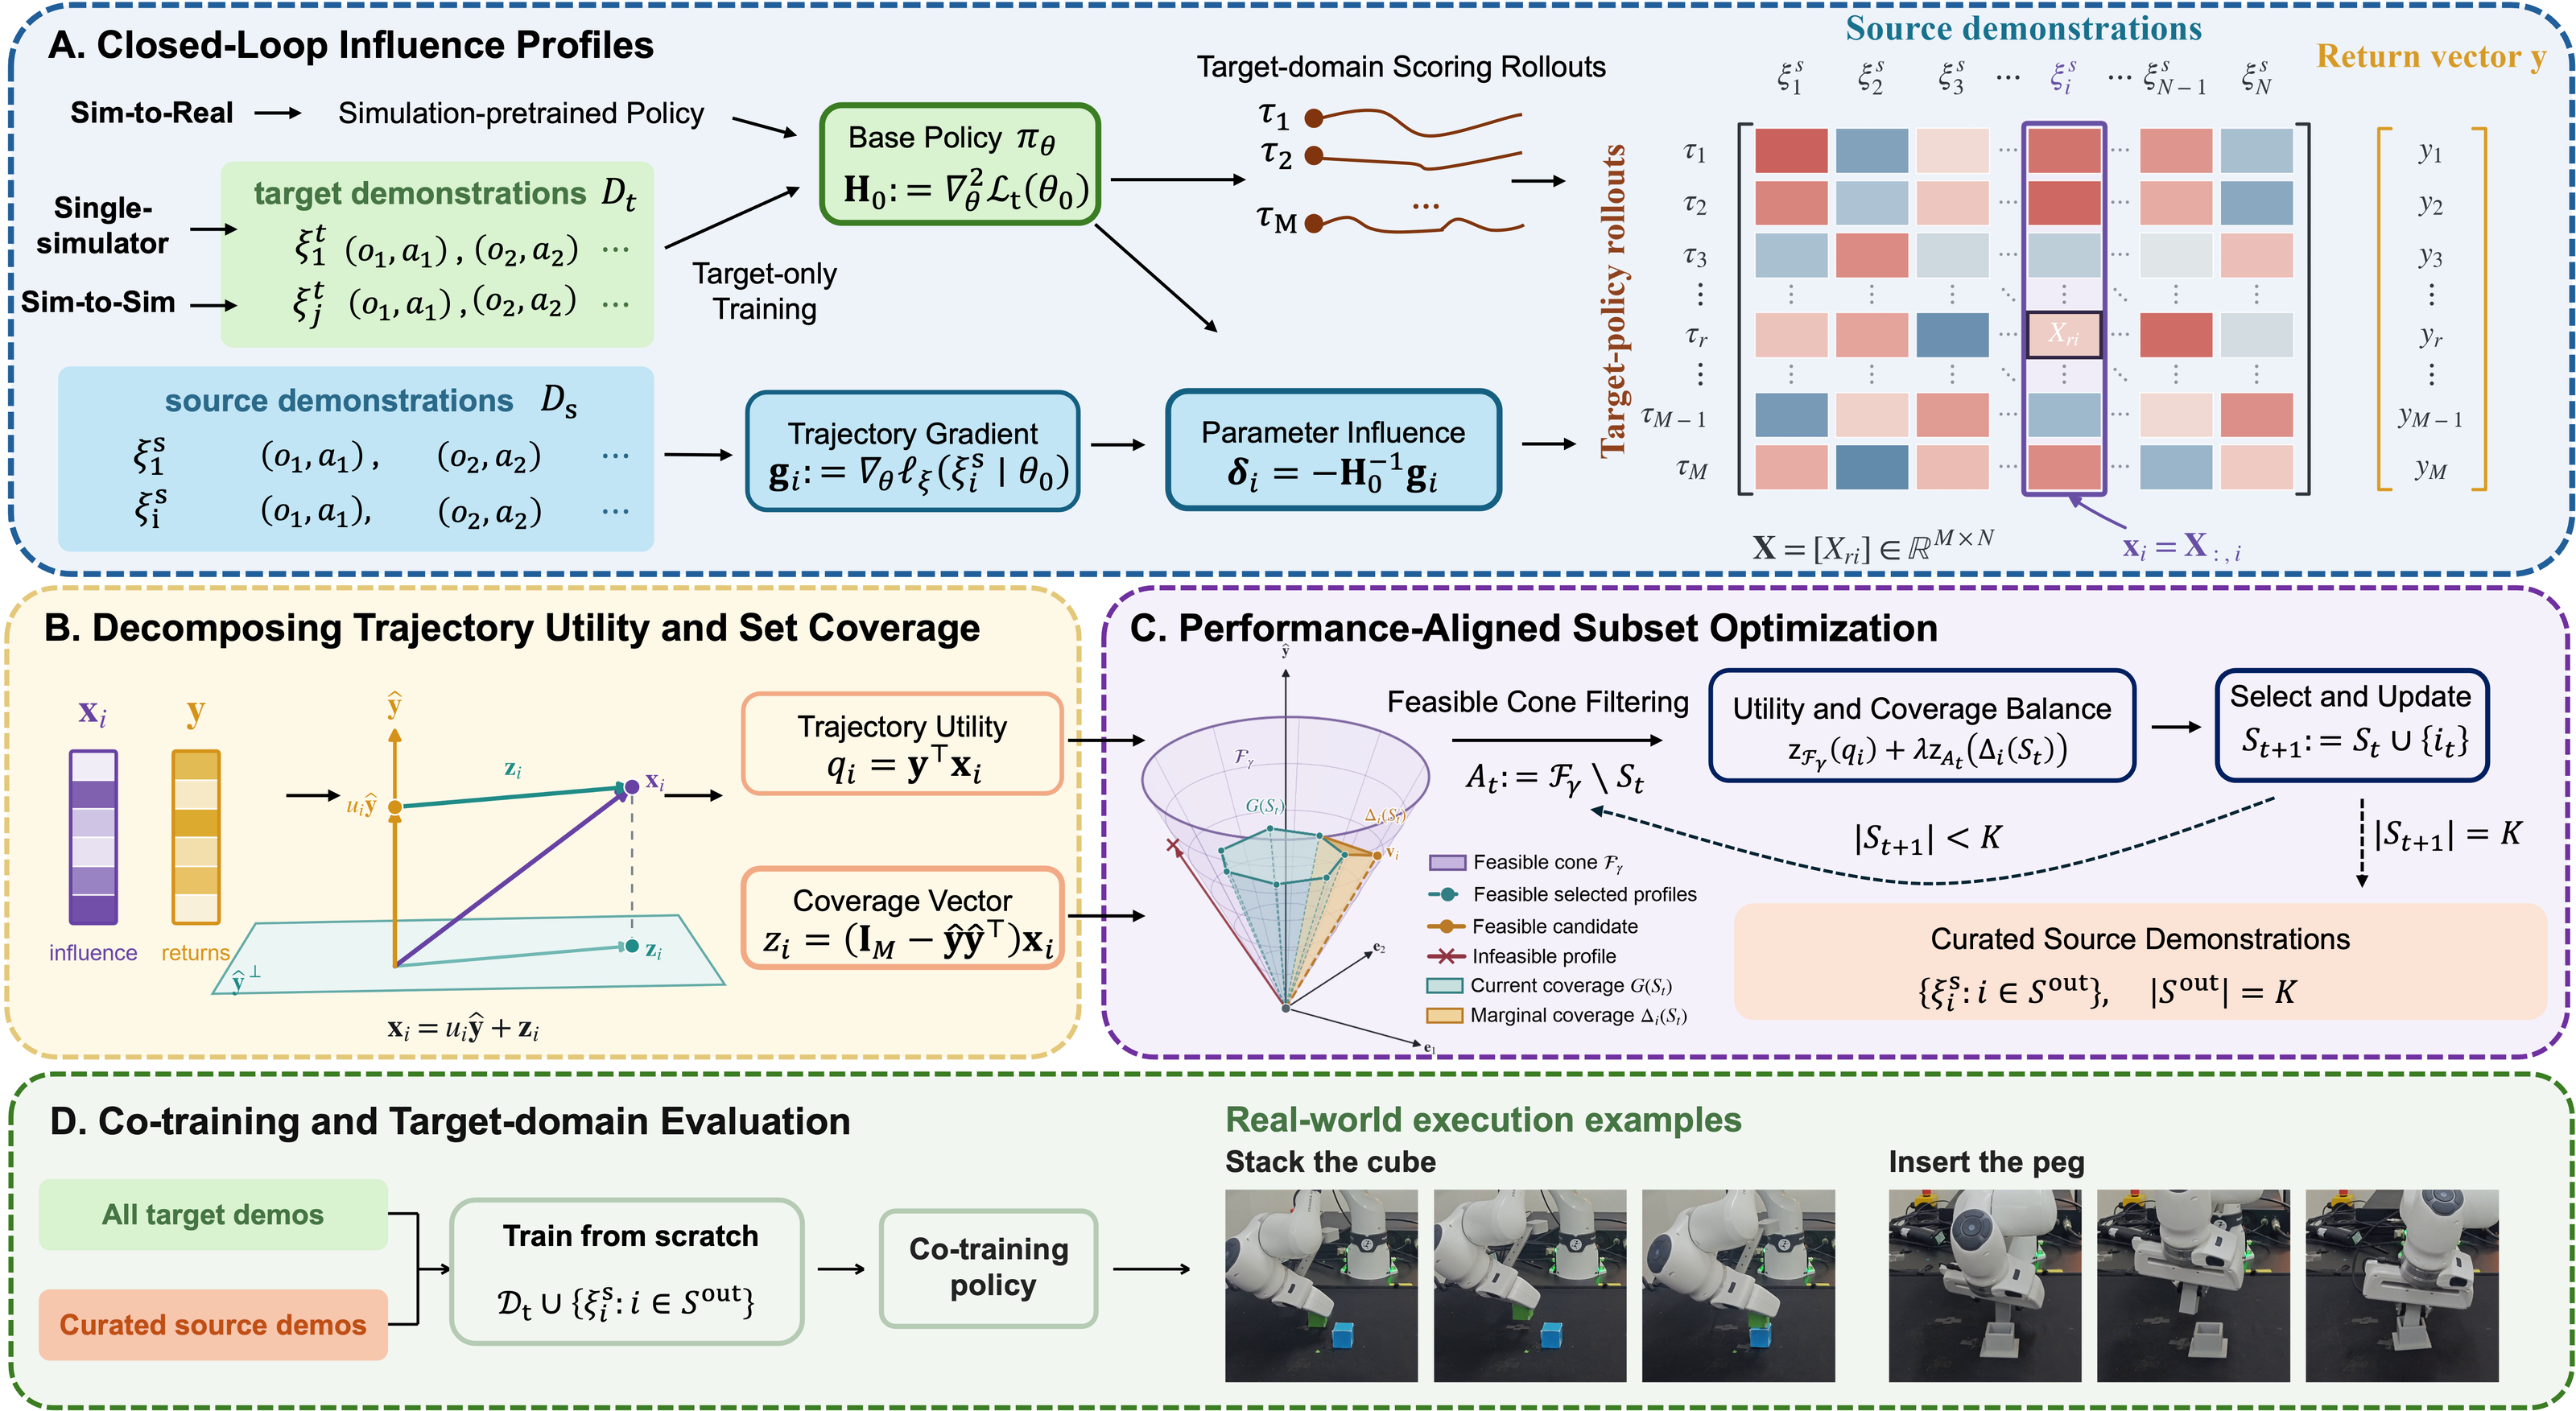
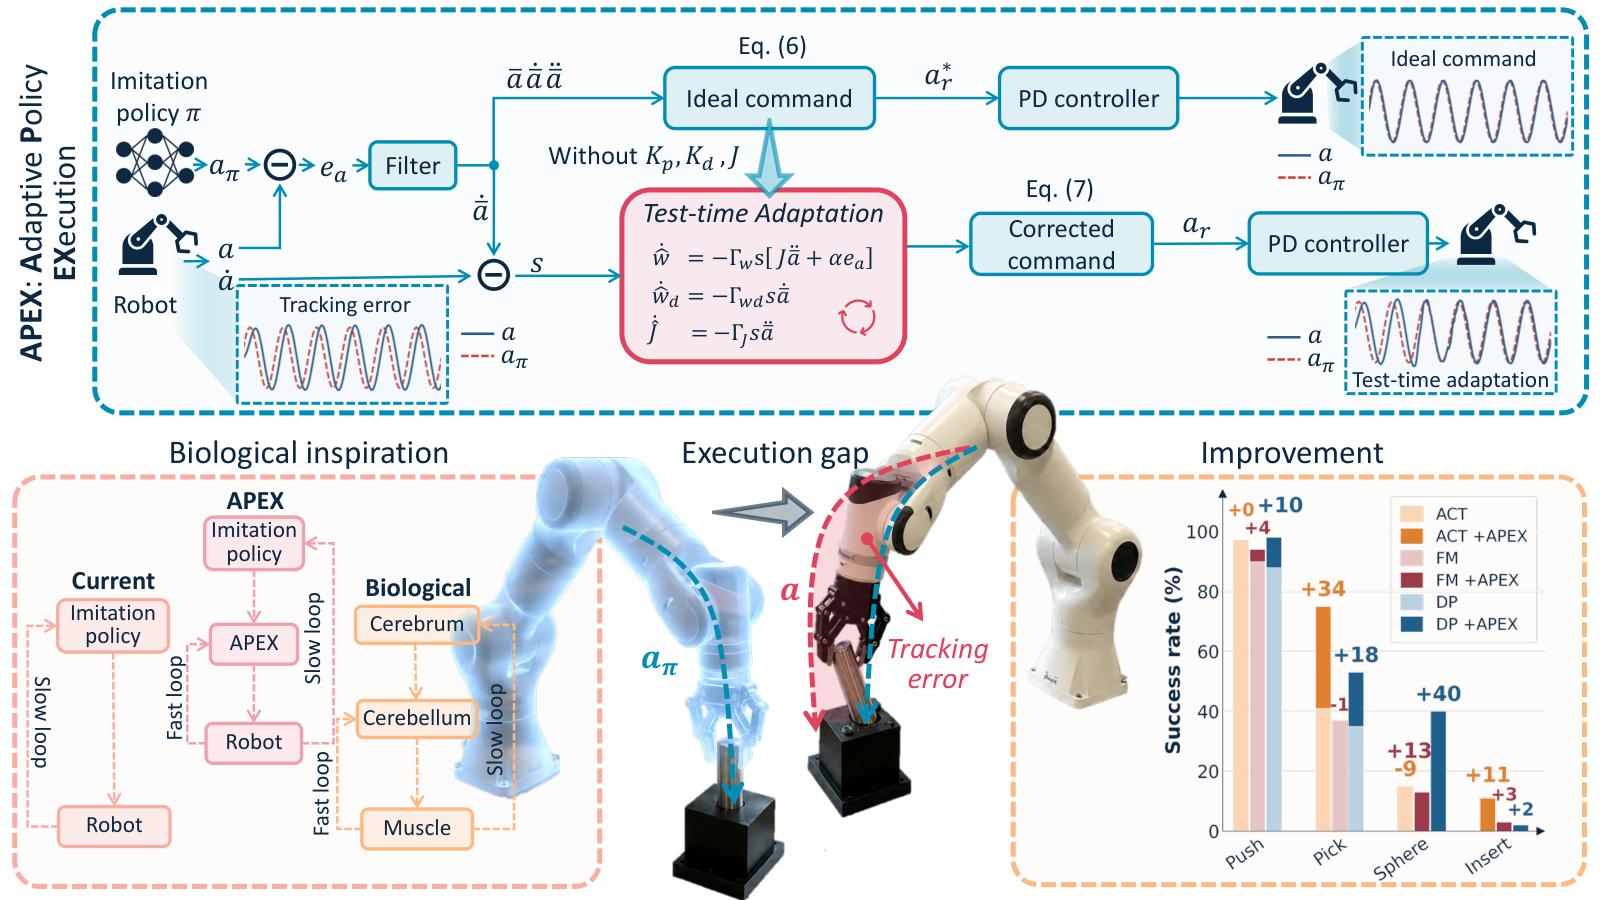
APEX: Adaptive Policy Execution for Precise Manipulation
In submission · ICRA
AURA: Adaptive Uncertainty Enables Emergent Robot Behaviors Without Scaling
Targeted: Science Robotics
Use action history and local action diversity to adapt uncertainty in generative policies, adjusting history, inference, and execution schedules.
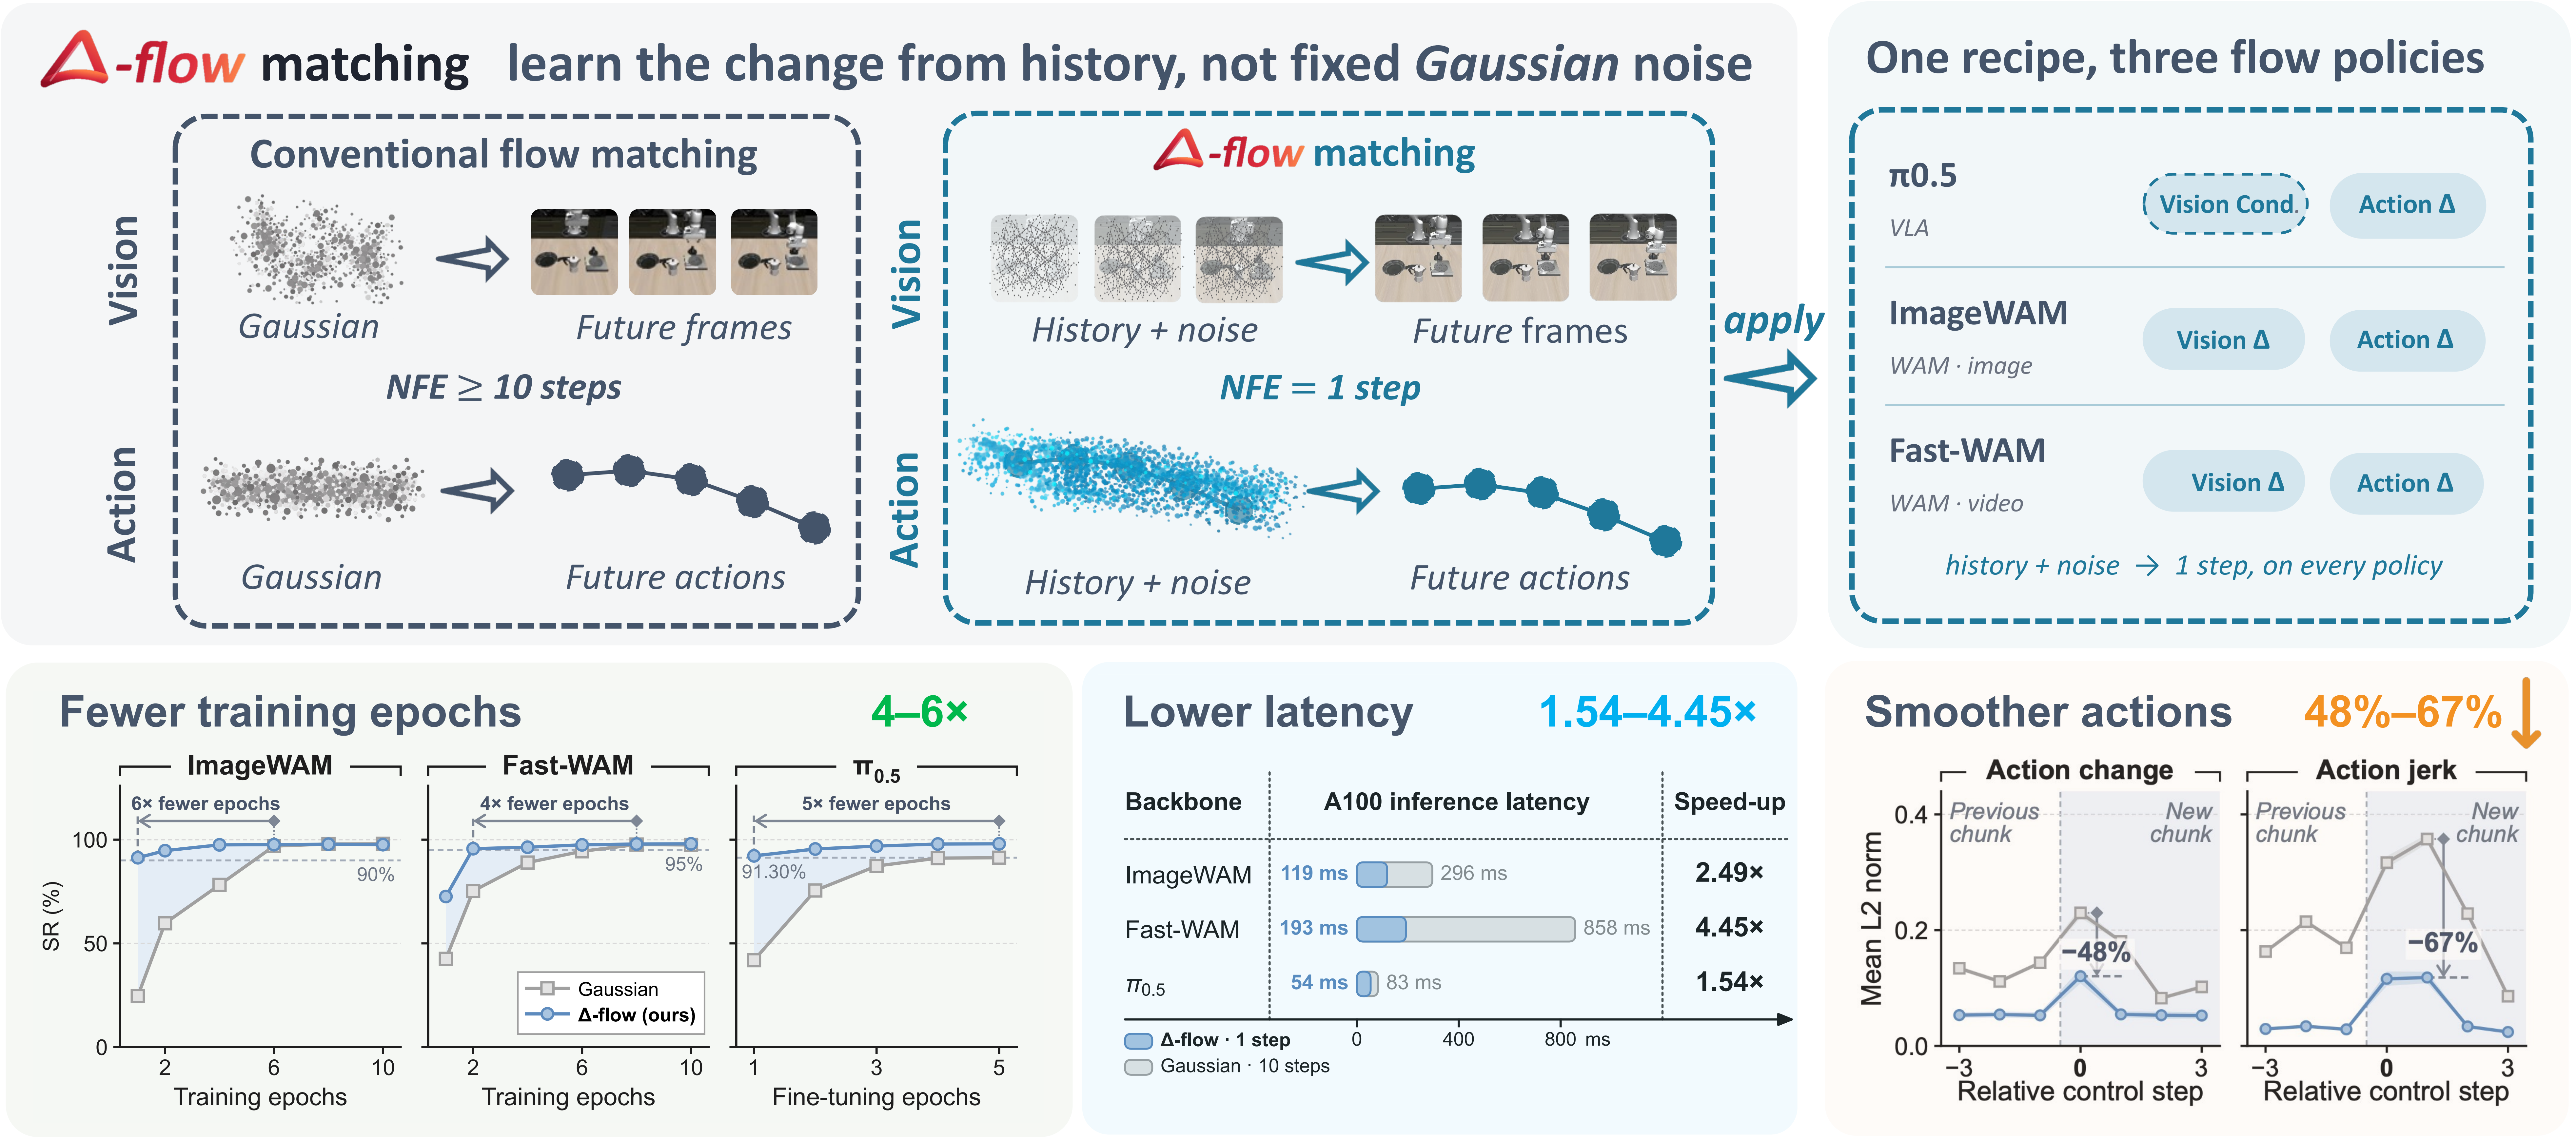
Δ Flow Matching for Robot Foundation Models
Start generation from recent action and visual history with light noise, learning changes from past to future to study training efficiency, single-step inference, and action smoothness.
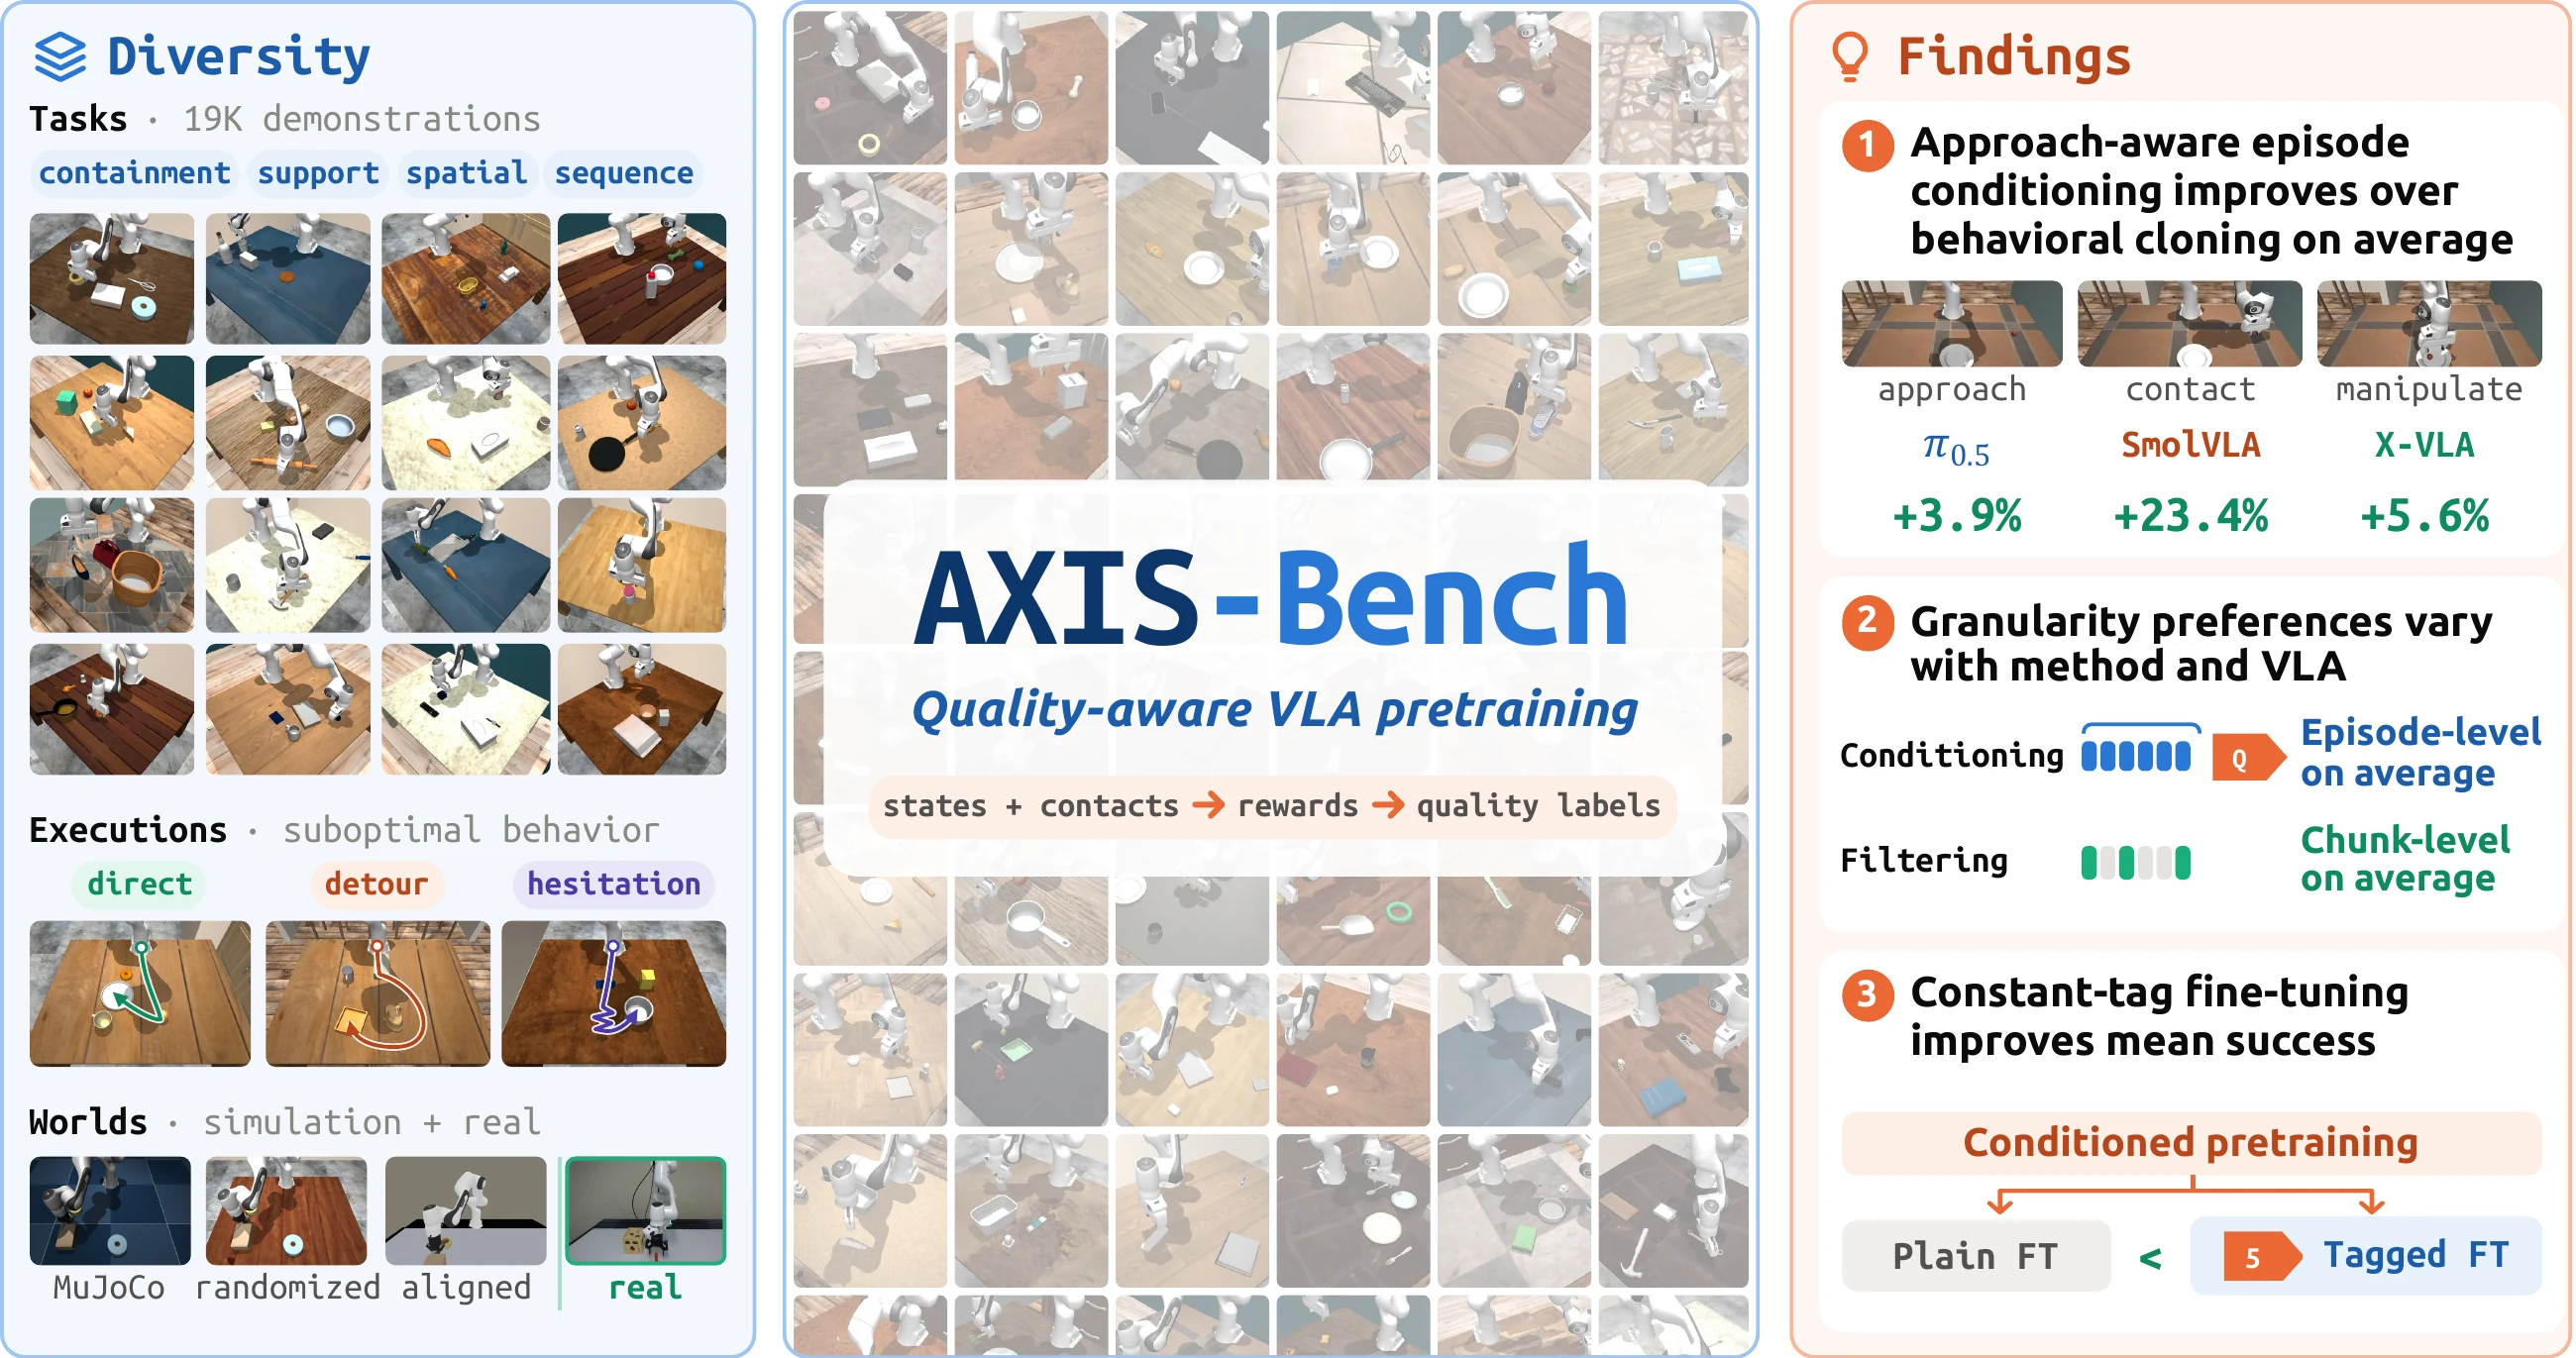
What Matters in Quality-Aware VLA Pretraining: A Benchmark and Empirical Study
In submission · ICRA
